24 avril 2026
Jean-Philippe Roberge
Professeur
Département
Département de génie des systèmes
Formation
B. Ing. (ÉTS), M. Sc. A. (Polytechnique Montréal), Ph. D. (ÉTS et Stanford)
Bureau
A-3642
Courriel
Présentation
Unité de recherche
Axes de recherche
- Capteurs, réseaux et connectivité
- Systèmes logiciels, multimédia et cybersécurité
Expertises
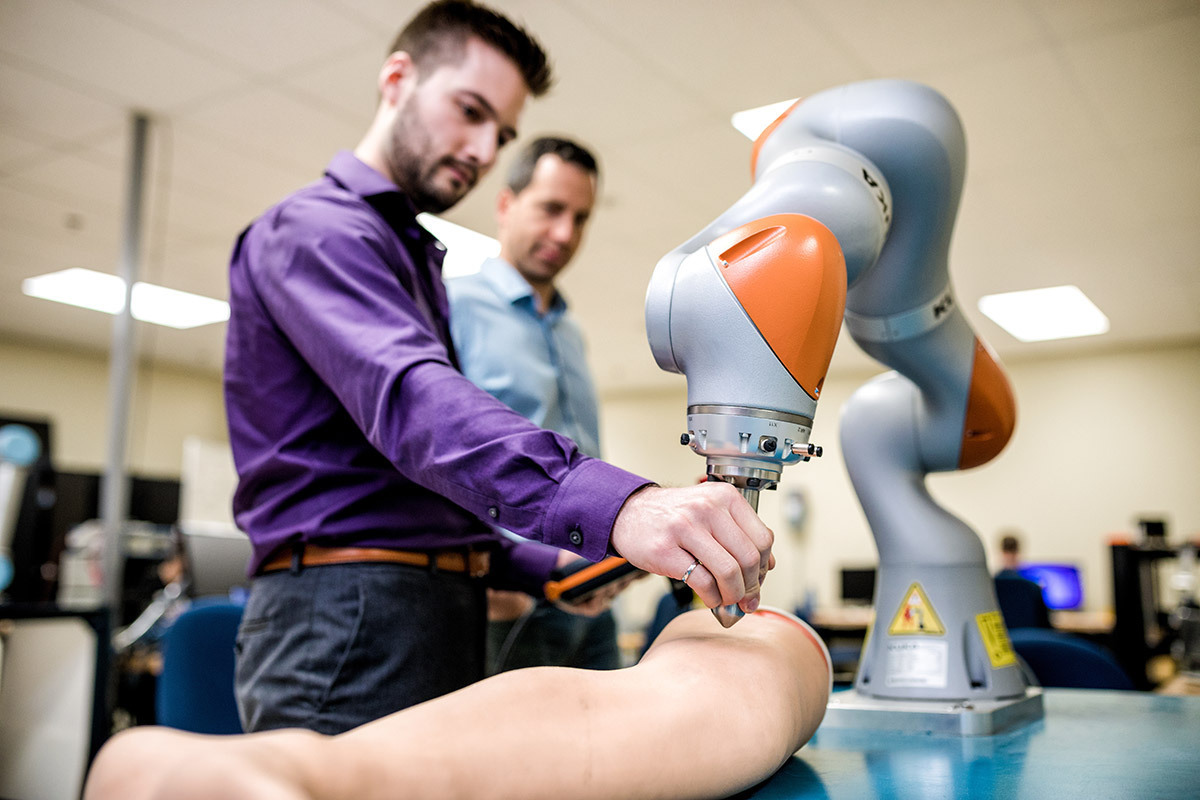
- Robotique
- Manipulation robotique
- Robotique collaborative
- Capteurs tactiles et visuels
- Intelligence tactile
- Commande linéaire et non-linéaire
- Robotique mobile
- Algorithmes embarqués
- Application de l'intelligence artificielle en robotique
Cours et encadrements
Cours
Encadrements
- Development of Machine Learning algorithms using synthetic visuotactile data for robotic manipulation, par Berith De La Cruz Sanchez
Automne 2026 - En codirection avec : François Michaud
Conception d'algorithmes d'apprentissage par renforcement avec modèle pour robot multisensoriel, par Guillaume Dupoiron
Automne 2026
- Development, Optimization and Application of the Stereotac Sensor in Simple and Semi-advanced Robotic Tasks, par Sajjad Ahangar
Automne 2026 - En codirection avec : Simon Joncas
Conception d'une cellule robotisée avec génération de programmes automatisés, par Camille Sauvain
Hiver 2023 - Mutual Capacitance Tactile Sensor Design and Sim-to-Real Bridging for Robotic Grasping, par Abed Al Rahman Al Mrad
Automne 2023 - Tri collaboratif de pièces semi-translucides et réflectives par intelligence artificielle, par Samuel Blanchet
Hiver 2024 - Téléopération d'un manipulateur robotisé par réalité virtuelle pour la maintenance et l'apprentissage de tâches, par Jonathan Boutin
Hiver 2025 - En codirection avec : Simon Joncas
Automatisation flexible des processus de programmation hors-ligne pour la production de masse de pièces unitaires en composite thermoplastique, par Ali Chokre
Été 2025 - En codirection avec : François Lebel
Développement d'une cellule automatisée de préparation d'ensembles prêts-à-monter multimatériaux pour la fabrication de composites en aérospatiale, par Diane Limes
Automne 2023 - En codirection avec : François Lebel
Conception axée sur la manufacturabilité d’un préhenseur robotique robuste : Un cas d’application pour la mise en place automatisée de plis multi-matières en support à la fabrication de pièces composites complexes, par Samuel Tétrault-Leclerc
Hiver 2024 - Design of a Collaborative Gripper for Foam Stickers Handling, par Francis Bilodeau
Automne 2023 - En codirection avec : Olivier Doutres
Développement d'un conduit auditif artificiel pour la mesure de pression mécanique statique générée par des bouchons à oreille, par Rihab Heni
Automne 2024 - En codirection avec : Christian Belleau
Planification de trajectoire et contrôle pour la course autonome par optimisation et apprentissage par renforcement, par Victor Dang
Automne 2026 - En codirection avec : Étienne Gendron
Génération automatique de trajectoire pour le grenaillage robotisé, par Sophie Diamond
Automne 2026 - En codirection avec : Étienne Gendron
Automated Surface Inspection for Reflective and Matte Curved Surfaces, par Ricardo Tovar
Automne 2026 - Conception et exploitation d’un capteur visuotactile stéréoscopique stéréophotometrique pour la manipulation robotique en environnement contraint, par Nimai Jariwala
Automne 2026
- Conception d'un banc de test instrumenté pour la validation des performances essentielles de l'ORTHOPUS Supporter, par Cassandra Seive
Hiver 2026 - Recherche et développement de systèmes de perçage intelligents pour la chirurgie du rachis, par Ronn Touitou
Été 2026 - En codirection avec : Nicholas Nadeau
Enhancing Robot Localization with Semantic Features: Creation of a Semantic Map for Autonomous Navigation Tasks, par Huynh-Anh Le
Hiver 2023 - En codirection avec : Marco Pedersoli
"Few-Shot Object Detection" et application "Pick and Place" dans le cadre d'un projet avec l'entreprise Teledyne Dalsa, par Antoine Bailly
Été 2023 - En codirection avec : Mahdi Khoramshahi
Pilotage d'un exosquelette pour membres supérieurs avec un casque EEG, par Hamsa Mousa
Été 2025 - En codirection avec : Rim Larbi
Algorithme d’évitements de collisions pour des robots Scara dans le cadre d’un projet avec l’entreprise Radiall, par Adam Alibert
Automne 2025
- Création d'une carte sémantique par caméra stéréoscopique qui sera utilisée pour faire de la navigation autonome, par Huynh-Anh Le
Hiver 2023
Publications
Publications
- Guillaume Dupoiron, François Michaud, Jean-Philippe Roberge. 2026 « Adaptive vision-based cleaning of industrial workstations using a collaborative mobile manipulator arm ». International Journal of Advanced Robotic Systems vol. 23 , nº 1
- Kourosh Jolaei, Jean-Philippe Roberge, Vincent Duchaine. 2026 « Shape-based extrapolation of contact patterns to support tactile regrasping ». Journal of Robotics and Mechatronics vol. 38 , nº 3. p. 740–752
- Berith Atemoztli Sánchez, Jean-Philippe Roberge. 2026 « A capacitive tactile sensor digital twin for real-time synthetic data generation and sim-to-real transfer in NVIDIA Isaac Sim ». Applied Sciences vol. 16 , nº 15
- Berith Atemoztli De la Cruz Sánchez, Jean-Philippe Roberge. 2025 « A hybrid elastic-hyperelastic approach for simulating soft tactile sensors ». Frontiers in Robotics and AI vol. 12
- Etienne Roberge, Guillaume Fornes, Jean-Philippe Roberge. 2023 « StereoTac: A novel visuotactile sensor that combines tactile sensing with 3D vision ». IEEE Robotics and Automation Letters vol. 8 , nº 10. p. 6291-6298
- Alexander Gruebele, Jean-Philippe Roberge, Andrew Zerbe, Wilson Ruotolo, Tae Myung Huh, Mark R. Cutkosky. 2020 « A stretchable capacitive sensory skin for exploring cluttered environments ». IEEE Robotics and Automation Letters vol. 5 , nº 2. p. 1750-1757
- Jean-Philippe Roberge, Wilson Ruotolo, Vincent Duchaine, Mark Cutkosky. 2018 « Improving industrial grippers with adhesion-controlled friction ». IEEE Robotics and Automation Letters vol. 3 , nº 2. p. 1041-1048
- M. Reza Motamedi, Jean-Philippe Roberge, Vincent Duchaine. 2017 « The Use of vibrotactile feedback to restore texture recognition capabilities, and the effect of subject training ». IEEE Transactions on Neural Systems and Rehabilitation Engineering vol. 25 , nº 8. p. 1230-1239
- Axaykumar Rana, Jean-Philippe Roberge, Vincent Duchaine. 2016 « An improved soft dielectric for a highly sensitive capacitive tactile sensor ». IEEE Sensors Journal vol. 16 , nº 22. p. 7853-7863
- Tony Wong, Pascal Bigras, Vincent Duchaine, Jean-Philippe Roberge. 2016 « Empirical comparison of differential evolution variants for industrial controller design ». International Journal of Computational Intelligence Systems vol. 9 , nº 5. p. 957-970
- Mark R. Cutkosky, Wilson Ruotolo, Jean-Philippe Roberge. 2020-12-29 « Patterned and instrumented directional adhesives for enhanced gripping with industrial manipulators ». Brevet américain US 10,875,190.
- Etienne Roberge, Guillaume Fornes, Jean-Philippe Roberge. 2024 « StereoTac: A novel visuotactile sensor that combines tactile sensing with 3D vision ». Communication lors de la conférence : IEEE International Conference on Robotics and Automation (ICRA) (Yokohama, Japan, May 13-17, 2024)
- Jean-Philippe Roberge, Louis L'Écuyer-Lapierre, Jennifer Kwiatkowski, Philippe Nadeau, Vincent Duchaine. 2021 « Tactile-based object recognition using a grasp-centric exploration ». Communication lors de la conférence : IEEE 17th International Conference on Automation Science and Engineering (CASE) (Lyon, France, Aug. 23-27, 2021)
- Jean-Philippe Roberge. 2020 « La manipulation avancée au service de la robotique collaborative ». Communication lors de la conférence : 3e édition du Forum d'été du CoRoM (En ligne, 8 mai 2020)
- Berith Atemoztli De La Cruz Sanchez, Jennifer Kwiatkowski, Jean-Philippe Roberge. 2025 « Tactile contact patterns for robotic grasping: A dataset of real and simulated data ». 3rd International Conference on Control and Robot Technology (ICCRT) (Singapore, Singapore, Apr. 16-18, 2025) Institute of Electrical and Electronics Engineers Inc.
- Jonathan Boutin, Guillaume Dupoiron, Jean-Philippe Roberge. 2024 « Virtual reality as a robot programming tool and a comparison of its effectiveness in common tasks ». IEEE 20th International Conference on Automation Science and Engineering (CASE) (Bari, Italy, Aug. 28-Sept. 01, 2024) IEEE Computer Society
- Rachel Thomasson, Etienne Roberge, Mark R. Cutkosky, Jean-Philippe Roberge. 2022 « Going in blind: Object motion classification using distributed tactile sensing for safe reaching in clutter ». IEEE International Conference on Intelligent Robots and Systems (Kyoto, Japan, Oct. 23-27, 2022) Institute of Electrical and Electronics Engineers Inc.
- Jean-Philippe Roberge, Louis L'Ecuyer-Lapierre, Jennifer Kwiatkowski, Philippe Nadeau, Vincent Duchaine. 2021 « Tactile-based object recognition using a grasp-centric exploration ». IEEE 17th International Conference on Automation Science and Engineering (CASE) (Lyon, France, Aug. 23-27, 2021) IEEE Computer Society
- Jennifer Kwiatkowski, Jean-Philippe Roberge, Nicholas A. Nadeau, Louis L'Écuyer-Lapierre, Vincent Duchaine. 2018 « An extrinsic dexterity approach to the IROS 2018 fan robotic challenge ». 2018 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) (Madrid, Spain, Oct. 1-5, 2018) IEEE
- Deen Cockburn, Jean-Philippe Roberge, Le Thuy-Hong-Loan, Alexis Maslyczyk, Vincent Duchaine. 2017 « Grasp stability assessment through unsupervised feature learning of tactile images ». 2017 IEEE International Conference on Robotics and Automation (ICRA) (Singapore, Singapore, May 29- June 03, 2017) IEEE
- Thuy-Hong-Loan Le, Alexis Maslyczyk, Jean-Philippe Roberge, Vincent Duchaine. 2017 « A highly sensitive multimodal capacitive tactile sensor ». 2017 IEEE International Conference on Robotics and Automation (ICRA) (Singapore, Singapore, May 29- June 03, 2017) IEEE
- M. Reza Motamedi, Jean-Baptiste Chossat, Jean-Philippe Roberge, Vincent Duchaine. 2016 « Haptic feedback for improved robotic arm control during simple grasp, slippage, and contact detection tasks ». 2016 IEEE International Conference on Robotics and Automation (ICRA) (Stockholm, Sweden, May 16-21, 2016) IEEE
- Jean-Philippe Roberge, Samuel Rispal, Tony Wong, Vincent Duchaine. 2016 « Unsupervised feature learning for classifying dynamic tactile events using sparse coding ». 2016 IEEE International Conference on Robotics and Automation (ICRA) (Stockholm, Sweden, May 16-21, 2016) IEEE
- M. Reza Motamedi, Jean-Philippe Roberge, Vincent Duchaine. 2015 « Tactile sensation transmission from a robotic arm to the human body via a haptic interface ». 2015 IEEE World Haptics Conference (WHC) (Evanston, Il, USA, June 22-26, 2015) IEEE